Level Measurement in Three-Phase Separators: Choosing Between DP, Radar, and Displacers
Get the oil–water interface wrong in a three-phase separator and the damage goes well past an off-spec product stream. Water carries over into the oil export line. Hydrocarbons carry under into produced-water disposal. And if the control loop starts hunting, downstream pressure swings and drags the whole separation train with it. Every one of those outcomes has a price tag, and the root cause is usually the same: an instrument picked without accounting for the emulsion band, fluid-density variability, or the mechanical realities of the installation.
What follows compares differential pressure (DP) transmitters, guided wave radar (GWR), and displacer-type instruments for bulk-level and interface measurement in horizontal three-phase separators. It is a basis for technology selection for instrument engineers and maintenance leads — not a vendor catalogue.
What the Measurement Must Actually Do
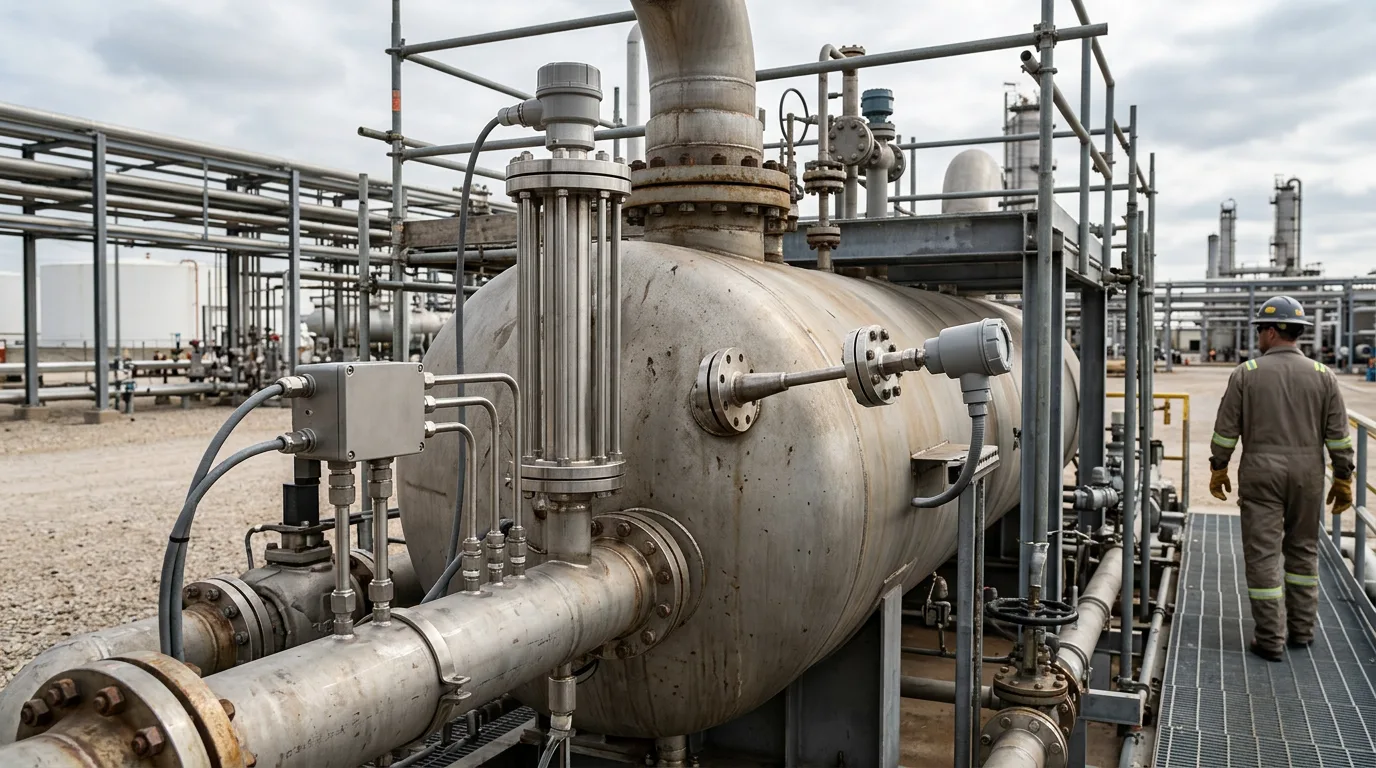
Inside a horizontal three-phase separator, two measurement jobs run at the same time. One tracks the hydrocarbon liquid level — the oil–gas interface near the top of the liquid body. The other tracks the oil–water interface near the bottom. Both feed control valves: the oil-level controller and the water-dump valve. Both can also be safety-instrumented functions under IEC 61511.
Then there is the emulsion layer sitting between the free-water phase and the clean-oil phase. Its thickness moves around with crude composition, temperature, chemical dosing, and throughput. An instrument that cannot tell the emulsion band apart from either clean phase will report a false interface position — and the water-dump valve will either flood the oil compartment or starve it.
Technology Comparison
Differential Pressure (DP) Transmitters
A DP transmitter infers liquid level from the hydrostatic head between two tapping points. In a three-phase separator, the classic arrangement puts a wet-leg or dry-leg reference on the high-pressure side, with a low-pressure tap near the vessel bottom.
The limitation is baked in: density dependence. The DP reading is the integrated density of whatever column of fluid sits between the taps. Shift the oil–water ratio — exactly what happens when a field moves from plateau production into water breakthrough — and the same DP reading now corresponds to a different physical interface position.
DP is also blind to the emulsion band. The transmitter sees a weighted average density across the measurement span. It cannot resolve a diffuse transition zone. Where the emulsion layer is persistent and thick, the interface reading is systematically biased.
The practical advantages have not gone anywhere: no moving parts in the process fluid (with remote seals), no process penetrations beyond the existing taps, and straightforward integration into existing DCS infrastructure. Maintenance teams understand DP, and calibration is traceable.
Displacer Transmitters
A displacer works on Archimedes' principle. A float of known volume sits partially submerged; the buoyancy force — and therefore the torque or force on the transmitter — varies with the density of the fluid around it. For interface measurement, the displacer is sized to sit at the oil–water boundary, and the change in buoyancy as it moves between phases produces a level signal.
Density dependence bites harder on displacers than on DP. A displacer is calibrated for one specific pair of fluid densities (oil SG and water SG). In practice, a displacer set up for produced water and 35°API crude will read wrong if the crude gravity shifts, or if produced-water salinity changes as the field ages.
Displacers also have moving parts — the torque tube, the float, the cage — and all of them sit in the process fluid. Scale, wax, asphaltene deposition, sand: any of these can bind the float mechanically or coat it. What you get is a stuck reading that the control system happily interprets as a stable level. In high-H₂S service, that sequence is safety-critical, not procedural.
None of that has pushed displacers out of service. In stable-density, clean-fluid applications they remain common. They are robust, mechanically simple, and familiar to field technicians.
Guided Wave Radar (GWR)
GWR sends a microwave pulse down a probe inserted into the vessel. The pulse reflects at dielectric discontinuities — the gas–liquid interface and, where the dielectric contrast is sufficient, the oil–water interface. Because the measurement is time-of-flight of an electromagnetic signal, fluid density does not enter into it. Shift the crude gravity or the produced-water salinity and the reading does not move.
Then comes the physical requirement that decides whether GWR works at all: dielectric contrast. To resolve the interface, GWR needs a meaningful difference in relative permittivity between the oil phase and the water phase. Fresh water and low-conductivity condensate can present too little contrast. High-water-cut emulsions with a gradual dielectric transition — not a sharp interface — weaken the reflected signal, and the instrument may end up tracking the mid-point of the emulsion band instead of the true free-water surface.
Select GWR probes for three-phase service with the emulsion layer thickness in mind. The probe has to be long enough to reach the water phase, and the nozzle location has to keep it clear of inlet momentum effects and weir turbulence.
Head-to-Head Summary
| Criterion | DP Transmitter | Displacer | Guided Wave Radar |
|---|---|---|---|
| Density independence | No — direct error with density shift | No — calibrated to specific densities | Yes |
| Simultaneous upper + interface | Requires two separate instruments | Requires two separate instruments | Single probe, two echoes |
| Emulsion band resolution | None — sees average density | None — float seeks buoyancy equilibrium | Partial — depends on dielectric contrast |
| Moving parts in process | None (with remote seals) | Yes — float, torque tube, cage | None |
| Maintenance access risk | Low | High — full isolation/depressurisation required | Low |
| Density-change recalibration | Required | Required | Not required |
| High-pressure suitability | Good | Good | Good — check probe rating |
Illustrative Scenario
The following is illustrative and does not represent a specific field event.
Take a horizontal three-phase separator on a platform where water cut has climbed steadily over several years. The displacer interface transmitter was calibrated at initial field conditions. As produced-water salinity rose and the crude lightened slightly, the buoyancy balance moved. The displacer kept reporting a stable interface. Meanwhile, operators were seeing more and more water in the oil export samples. Investigation found the displacer float reading high against the true interface — the control valve was holding the water level lower than intended, so water accumulated in the oil compartment.
Swapping the displacer for a GWR unit on the same nozzle, probe extended to the vessel floor, fixed the interface tracking. The density shift that had thrown the displacer off meant nothing to the radar measurement. The DP transmitter kept for bulk-level control was recalibrated to the updated fluid densities at the same time.
Decision Guidance
Before picking a technology for a new installation or a like-for-like replacement, work through the following:
- First question: will fluid density stay put over the expected field life, or will water cut, crude gravity, or produced-water salinity move enough to matter?
- If density will change, DP and displacers require recalibration each time. Put that in the lifecycle cost and the operational risk column.
- Quantify the emulsion band. If the separator routinely carries a thick, diffuse emulsion layer, no current technology gives a clean interface signal — but GWR will at least track the dielectric transition, while DP and displacers average through it silently.
- Check the dielectric contrast between the oil and water phases. If relative permittivity values are close (low-salinity water, light condensate), GWR interface detection may be unreliable; consult the vendor with actual fluid data.
- For safety-instrumented level functions, confirm the selected technology meets the required SIL under
IEC 61511and that proof-test intervals are achievable without compromising process availability. - For displacer maintenance, get the isolation, depressurisation, zero-energy verification, LOTO, gas detection, and venting procedures documented and trained before anyone raises a work order.
- In high-H₂S or high-pressure service, weight the maintenance-access risk heavily. The reduced intervention frequency of GWR is operationally significant.
- On critical separators, consider a dual-technology approach: GWR for interface tracking and a DP transmitter as an independent level check, with the two signals cross-validated in the DCS.
Conclusion
No single technology is universally correct for three-phase separator level measurement. DP transmitters are reliable for stable-density bulk-level service, but they fail silently when density shifts. Displacers are mechanically proven, yet they carry density-calibration sensitivity and a moving-parts maintenance burden that turns into a liability in high-H₂S or scaling service. Guided wave radar removes the density-dependence problem and can provide simultaneous upper-level and interface measurement from a single probe, but it requires adequate dielectric contrast and careful probe selection for emulsion-heavy service.
For any project or brownfield review, the next step is characterising the actual fluid properties — density variability over field life and emulsion-band behaviour included — before writing the instrument data sheet. Select against real process data rather than a default specification, and you avoid most of the interface-measurement failures that drive separator upsets and off-spec product.